ZYY Robot Arm Model
The zyy robot model simulates a three-DOF robot arm structured as a two-link arm on a rotating base. The base joint1 rotates around the vertical Z axis, followed by a shoulder joint2 around the horizontal Y axis and elbow joint3, parallel to joint2 around the Y axis. The reference pose is straight up. The arm has a distance sensor at the end. The model is intended as a demonstration testbed for zyy kinematics.
The link geometry uses only cylinder primitives. The same geometry is referenced to use as bounding objects for collision and automatic calculation of physics parameters. The base object has a NULL Physics object so it does not move, simulating a rigid connection to the ground.
The end sensor is represented by a yellow cone. It is implemented as a DistanceSensor of limited range, pointing outward along the link axis from the end of the second link.
This model is demonstrated in the zyy.wbt world.
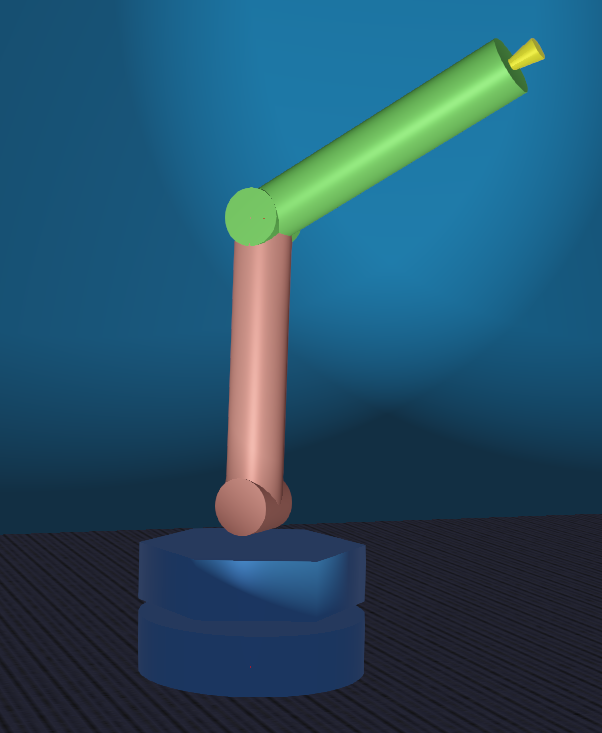
Screenshot of Webots zyy robot arm robot model.
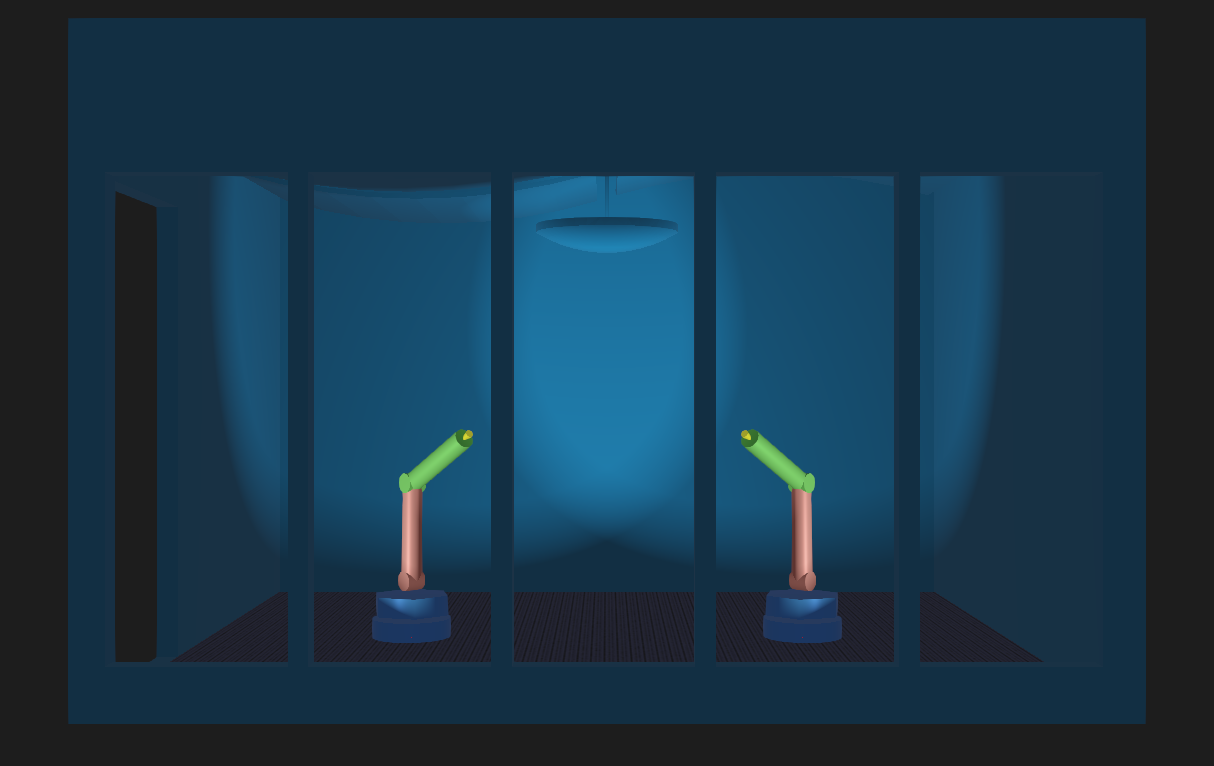
Screenshot of Webots sample world zyy.wbt with two zyy robot arms in the HL A11 room.
System Kinematics
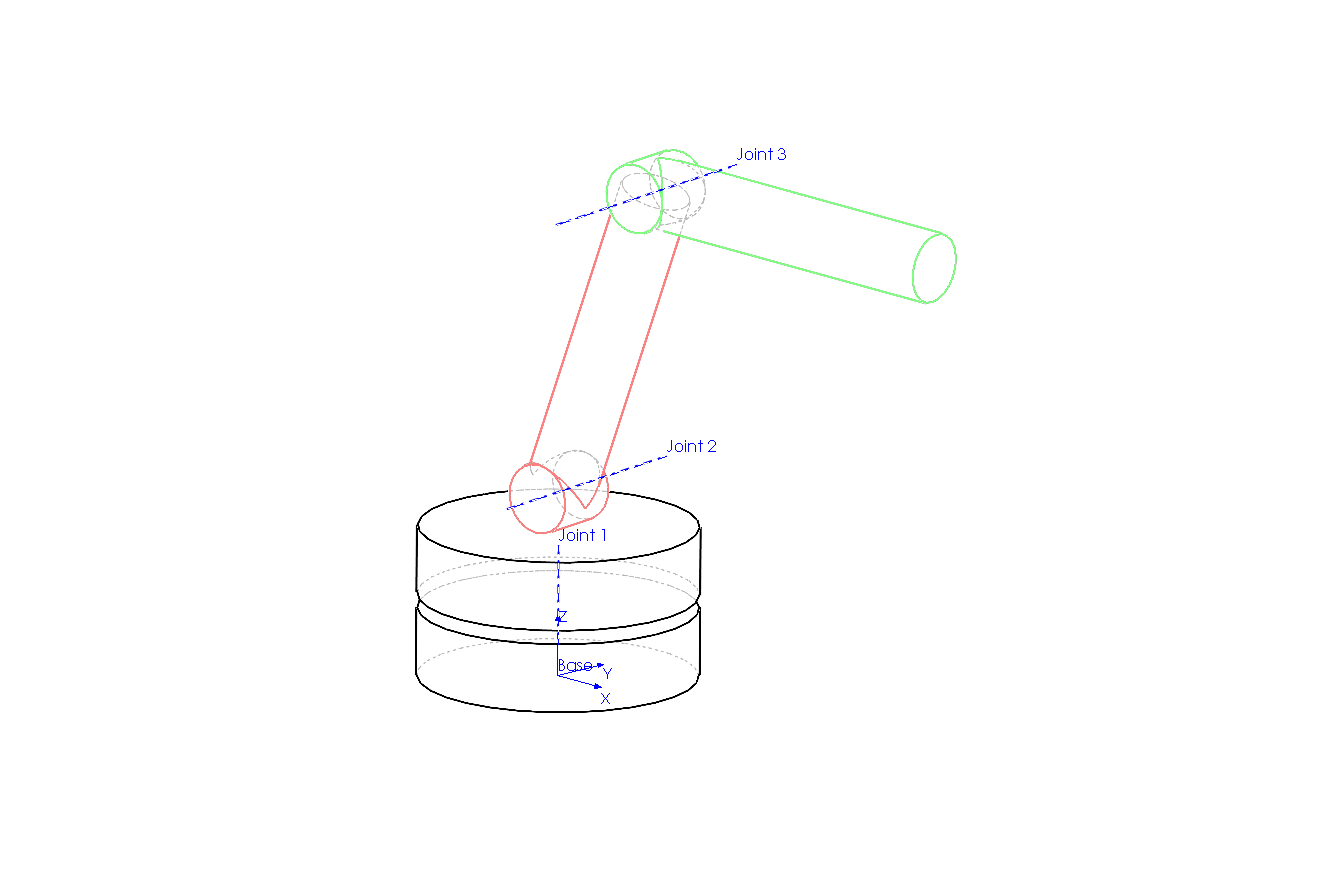
Kinematic diagram of the zyy robot arm model.
The bodies are as follows:
name |
color |
notes |
|---|---|---|
fixed |
blue |
base object fixed to the ground |
base |
blue |
upper base element rotating around the Z axis |
link1 |
red |
proximal link, attaches to base at ‘shoulder’ |
link2 |
green |
the distal link, attaches to link1 at ‘elbow’ |
The joints are as follows:
name |
parent |
child |
notes |
|---|---|---|---|
joint1 |
fixed |
base |
the base pivot, includes motor1 |
joint2 |
base |
link1 |
the ‘shoulder’, includes motor2 |
joint3 |
link1 |
link2 |
the ‘elbow’, includes motor3 |
The joint limits are as follows:
name |
min deg |
max deg |
description |
|---|---|---|---|
joint1 |
-120 |
120 |
symmetric pivot around vertical axis |
joint2 |
-5 |
90 |
from slight reverse down to link1 horizontal |
joint3 |
-5 |
120 |
from slight reverse down to an acute retraction |
The axes are as follows:
name |
direction |
notes |
|---|---|---|
joint1 |
along Z |
located above the origin |
joint2 |
along Y |
located above the origin |
joint3 |
along Y |
located at the end of link1 |
The motors and sensors are named as follows:
name |
notes |
|---|---|
motor1 |
RotationalMotor on joint1 |
motor2 |
RotationalMotor on joint2 |
motor3 |
RotationalMotor on joint3 |
joint1 |
PositionSensor on joint1 |
joint2 |
PositionSensor on joint2 |
joint3 |
PositionSensor on joint3 |
endRangeSensor |
DistanceSensor at end of link2 |
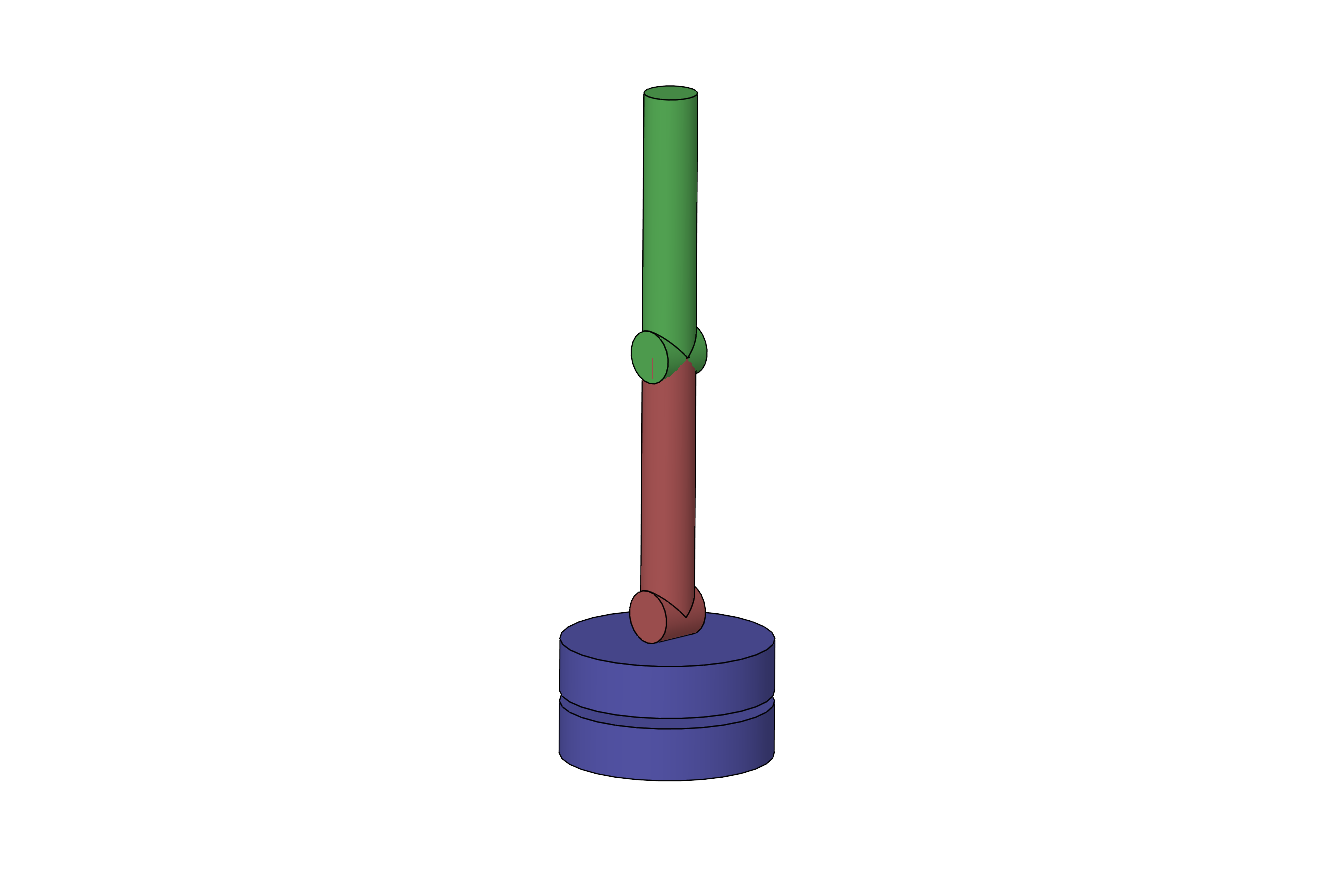
Reference pose of the zyy robot arm model: all joints are zero when the arm is pointing straight up.
zyy.proto
The robot model has been encapsulated in a .proto file for easy reuse. The model includes user-accessible link length parameters to demonstrate procedural scaling.
  1#VRML_SIM R2023b utf8
  2#
  3# Two-link actuated arm featuring three degreees of freedom.  The first axis is
  4# a base rotation around Z, followed by two arm joints rotating around Y.  The
  5# graphics use only cylinder and cone primitives.  The base has NULL physics so
  6# it will be fixed in place. The two link lengths are adjustable parameters to
  7# demonstrate using procedural elements in the prototype.  The link physics
  8# properties are specified using density so the dynamics will also scale, but
  9# the motor parameters are constant.  The end includes a distance sensor pointed
 10# along the second link axis.
 11#
 12# documentation url: https://courses.ideate.cmu.edu/16-375
 13# license: No copyright, 2020-2026 Garth Zeglin.  This file is explicitly placed in the public domain.
 14# template language: javascript
 15
 16PROTO zyy [
 17  field SFVec3f    translation  0 0 0
 18  field SFRotation rotation     0 1 0 0
 19  field SFFloat    link1Length  0.5
 20  field SFFloat    link2Length  0.5
 21  field SFString   controller   "zyy"
 22  field SFString   name         ""
 23  field SFString   customData   ""
 24]
 25{
 26  Robot {
 27    # connect properties to user-visible data fields
 28    translation IS translation
 29    rotation IS rotation
 30    controller IS controller
 31    name IS name
 32    customData IS customData
 33
 34    # calculate derived parameters
 35    %<
 36      let halfLink1Len = fields.link1Length.value / 2;
 37      let halfLink2Len = fields.link2Length.value / 2;
 38    >%
 39
 40    # define the kinematic tree
 41    children [
 42      # add a default radio receiver and transmitter
 43      Receiver {
 44        channel 1
 45      }
 46      Emitter {
 47        channel 1
 48      }
 49
 50      # the cylindrical base shape is wrapped in a Pose
 51      # to position it within the robot body coordinates
 52      DEF fixedBaseShape Pose {
 53        translation 0 0 0.05
 54        children [
 55          Shape {
 56            appearance DEF blueAppearance PBRAppearance {
 57              baseColor 0.21529 0.543008 0.99855
 58              metalness 0.5
 59 	      roughness 0.5
 60            }
 61            geometry Cylinder {
 62              height 0.1
 63              radius 0.2
 64            }
 65          }
 66        ]
 67      }
 68
 69      # define the base Z-axis pivot connecting the fixed base and the rotating base
 70      HingeJoint {
 71        jointParameters HingeJointParameters {
 72          axis 0 0 1
 73          # limit travel to (-120, 120) degrees
 74	  minStop -2.0943951023931953
 75	  maxStop 2.0943951023931953
 76        }
 77        device [
 78          PositionSensor {
 79            name "joint1"
 80          }
 81          RotationalMotor {
 82            name "motor1"
 83            acceleration 2
 84            maxVelocity 3.14
 85            maxTorque 20
 86          }
 87        ]
 88        # define rotating base element
 89        endPoint Solid {
 90          translation 0 0 0.120
 91          name "base"
 92          children [
 93            DEF rotatingBaseShape Pose {
 94              translation 0 0 0.050
 95              children [
 96                # rotating base geometry
 97                Shape {
 98                  appearance USE blueAppearance
 99                  geometry Cylinder {
100                    height 0.100
101                    radius 0.200
102		    subdivision 6
103                  }
104                }
105              ]
106            }
107            # define the j2 Y axis pivot connecting the rotating base and the first arm link
108            HingeJoint {
109              jointParameters HingeJointParameters {
110                axis 0 1 0
111                anchor 0 0 0.170
112                # limit travel to (-5, 90) degrees
113	  	minStop -0.08726646259971647
114	  	maxStop 1.5707963267948966
115              }
116              device [
117                PositionSensor {
118                  name "joint2"
119                }
120                RotationalMotor {
121                  name "motor2"
122                  acceleration 2
123                  maxVelocity 3.14
124                  maxTorque 20
125                }
126              ]
127              # start definition of the first link
128              endPoint Solid {
129                # place the shape origin halfway along the first link;
130                # this vector is in base coordinates, Z points along
131                # the link in the neutral pose
132                translation 0 0 %<=halfLink1Len+0.17>%
133
134                children [
135                  # define the j3 Y-axis 'elbow' pivot connecting the links
136                  HingeJoint {
137                    jointParameters HingeJointParameters {
138                      axis 0 1 0
139                      # place the elbow joint axis at the end of the first
140                      # link; position is relative to link1 origin
141                      anchor 0 0 %<= halfLink1Len >%
142                      dampingConstant 0.1
143                      # limit travel to (-5, 120) degrees
144		      minStop -0.08726646259971647
145		      maxStop 2.0943951023931953
146                    }
147                    device [
148                      PositionSensor {
149                        name "joint3"
150                      }
151                      RotationalMotor {
152                      name "motor3"
153                      acceleration 2
154                      maxVelocity 6.28
155                      maxTorque 15
156                      }
157                    ]
158                    # define the second link
159                    endPoint Solid {
160                      # place the link2 origin halfway along the second link
161                      translation 0 0 %<= halfLink1Len+halfLink2Len>%
162                      children [
163                        # the cylindrical link shape is wrapped in a Pose
164                        # to position it within the link2 coordinates
165                        DEF link2Shape Pose {
166                          # the Cylinder shape coordinates use Z as the
167                          # long axis; this 90 deg rotation around Y
168                          # places the lengthwise Z axis along the link.
169                          children [
170                            Shape {
171                              appearance DEF greenAppearance PBRAppearance {
172                                baseColor 0.413001 1 0.33489
173                                metalness 0.5
174                   	        roughness 0.5
175                              }
176                              geometry Cylinder {
177                                height IS link2Length
178                                radius 0.05
179                              }
180                            }
181                         ]
182                       } # end link2 Shape
183                       # add a visual hub to the base of link2, not part of the bounding object
184                       Pose {
185                          rotation 1 0 0 1.5708
186                          translation 0 0 %<= -halfLink2Len>%
187                              children [
188                                Shape {
189                              appearance USE greenAppearance
190                              geometry Cylinder {
191                                    height 0.1
192                                    radius 0.05
193                                  }
194                                }
195                              ]
196                       } # end Pose around link2 base hub
197                       # define a DistanceSensor attached to the second link Solid node
198                       DistanceSensor {
199                         translation 0 0 %<= halfLink2Len>%
200                         name "endRangeSensor"
201
202                         # the sensor lookup table implicitly defines the maximum range and the units, each
203                         # entry is [distance, value, noise]
204                         lookupTable [
205                           0 0 0
206                           0.9 0.9 0    # 0.9 meters reads as 0.9 meters
207                         ]
208                         resolution 0.001 # assume millimeter resolution
209                         numberOfRays 5
210                         aperture 0.1
211                         children [
212                           Pose {
213                             # flip the cone representing the sensor so the base is up
214                             rotation 0 1 0 3.14159
215                             children [
216                               Shape {
217                                 appearance PBRAppearance {
218                                   baseColor 1 0.99028 0.0584421
219                                   roughness 0.5
220                                   metalness 0.5
221                                   emissiveColor 1 0.99028 0.0584421
222                                   emissiveIntensity 0.2
223                                 }
224                                 geometry Cone {
225                                   bottomRadius 0.02
226                                   height 0.1
227                                 }
228                               }
229                             ]
230                           }
231                         ]
232                       } # end DistanceSensor
233                      ] # end link2 Solid children
234                      # top-level properties of link2
235                      name "link2"
236                      boundingObject USE link2Shape
237                      physics Physics {
238                        # Assume the link is a thin-walled aluminum tube with 50 mm
239                        # radius and 2 mm wall thickness.  Aluminum has a density of
240                        # 2700 kg/m^3, but this will be scaled by the ratio of the
241                        # tube cross-section to the solid cylinder cross-section
242                        # assumed by the simulator.  Note that the moment of inertia
243                        # around the long axis will be underestimated.
244                        # density = 2700 * (R_outer**2 - R_inner**2) / R_outer**2
245                        density 211.7
246                        mass -1
247                      }
248                    }
249                  }
250                  # finish the definition of link1 with a shape
251                  # node in the 'children' list
252                  DEF link1Shape Pose {
253                    children [
254                      Shape {
255                        appearance DEF redAppearance PBRAppearance {
256                           baseColor 00.990494 0.516915 0.468254
257                           metalness 0.5
258			   roughness 0.5
259                        }
260                        geometry Cylinder {
261                          height IS link1Length
262                          radius 0.05
263                        }
264                      }
265                     ]
266                   }
267                   # add a visual hub to the base of link1, not part of the bounding object
268                   Pose {
269                      rotation 1 0 0 1.5708
270                      translation 0 0 %<= -halfLink1Len>%
271                      children [
272                        Shape {
273                          appearance USE redAppearance
274                          geometry Cylinder {
275                            height 0.1
276                            radius 0.05
277                          }
278                        }
279                      ]
280                   } # end Pose around link1 base hub
281                ] # close the children list of the link1 node
282                # top-level properties of link1
283                name "link1"
284                boundingObject USE link1Shape
285                physics Physics {
286                  # See notes for link2 density; this assumes the same geometry.
287                  density 211.7
288                  mass -1
289                } # close the Physics for the first arm link
290              } # close the Solid in the HingeJoint endpoint
291            } # close the HingeJoint between the base and the first arm link
292          ] # close the children of the rotating base
293	  # the rotating robot base participates in collisions
294          boundingObject USE rotatingBaseShape
295	  # the rotating robot base has some mass and physics
296	  physics Physics {
297	    mass 2.0
298	    density -1
299          }
300        } # close the Solid in the base axis HingeJoint endpoint
301      } # close the HingeJoint between the fixed and rotating base
302    ] # close the children list of the base Robot node
303
304    # the fixed robot base participates in collision
305    boundingObject USE fixedBaseShape
306
307    # the base of the robot itself has NULL physics to simulate being fixed to the ground
308
309  } # close the Robot definition
310}
Sample Control Code
  1# zyy.py
  2#
  3# Sample Webots controller file for driving a two-link arm with three driven
  4# joints.  This example provides inverse kinematics for performing
  5# position-controlled trajectories.
  6
  7# No copyright, 2020-2024, Garth Zeglin.  This file is
  8# explicitly placed in the public domain.
  9
 10print("zyy.py waking up.")
 11
 12# Import the Webots simulator API.
 13from controller import Robot
 14
 15# Import the standard Python math library.
 16import math, random, time
 17
 18# Import the bezier module from the same directory.  Note: this requires numpy.
 19import bezier
 20
 21# Import the third-party numpy library for matrix calculations.
 22# Note: this can be installed using 'pip3 install numpy' or 'pip3 install scipy'.
 23import numpy as np
 24
 25# Define the time step in milliseconds between controller updates.
 26EVENT_LOOP_DT = 20
 27
 28################################################################
 29class ZYY(Robot):
 30    def __init__(self):
 31
 32        super(ZYY, self).__init__()
 33        self.robot_name = self.getName()
 34        print("%s: controller connected." % (self.robot_name))
 35
 36        # Attempt to randomize the random library sequence.
 37        random.seed(time.time())
 38
 39        # Initialize geometric constants.  These should match
 40        # the current geometry of the robot.
 41        self.base_z  = 0.29  # joint2 axis height: 0.12 fixed base height + 0.17 j2 z offset
 42        self.link1   = 0.5   # link1 length, i.e. distance between j2 and j3
 43        self.link2   = 0.5   # link2 length, i.e. distance between j3 and end
 44
 45        # Fetch handles for the joint motors.
 46        self.motor1 = self.getDevice('motor1')
 47        self.motor2 = self.getDevice('motor2')
 48        self.motor3 = self.getDevice('motor3')
 49
 50        # Adjust the motor controller properties.
 51        self.motor1.setAvailableTorque(20.0)
 52        self.motor2.setAvailableTorque(15.0)
 53        self.motor3.setAvailableTorque(10.0)
 54
 55        # Adjust the low-level controller gains.
 56        print("%s: setting PID gains." % (self.robot_name))
 57        self.motor1.setControlPID(100.0, 0.0, 25.0)
 58        self.motor2.setControlPID( 50.0, 0.0, 15.0)
 59        self.motor3.setControlPID( 50.0, 0.0, 15.0)
 60
 61        # Fetch handles for the joint sensors.
 62        self.joint1 = self.getDevice('joint1')
 63        self.joint2 = self.getDevice('joint2')
 64        self.joint3 = self.getDevice('joint3')
 65
 66        # Specify the sampling rate for the joint sensors.
 67        self.joint1.enable(EVENT_LOOP_DT)
 68        self.joint2.enable(EVENT_LOOP_DT)
 69        self.joint3.enable(EVENT_LOOP_DT)
 70
 71        # Connect to the end sensor.
 72        self.end_sensor = self.getDevice("endRangeSensor")
 73        self.end_sensor.enable(EVENT_LOOP_DT) # set sampling period in milliseconds
 74        self.end_sensor_interval = 1000
 75        self.end_sensor_timer = 1000
 76
 77        # Initialize behavior state machines.
 78        self.state_timer = 2*EVENT_LOOP_DT
 79        self.state_index = 0
 80        self._init_spline()
 81        return
 82
 83    #================================================================
 84    def endpoint_forward_kinematics(self, q):
 85        """Compute the forward kinematics for the end point.  Returns the
 86        body-coordinate XYZ Cartesian position of the end point for a given joint
 87        angle vector.
 88        :param q: three-element list with [q1, q2, q3] joint angles in radians
 89        :return:  three-element list with endpoint [x,y,z] location
 90
 91        """
 92        j1 = q[0]
 93        j2 = q[1]
 94        j3 = q[2]
 95
 96        return [(self.link1*math.sin(j2) + self.link2*math.sin(j2 + j3))*math.cos(j1),
 97                (self.link1*math.sin(j2) + self.link2*math.sin(j2 + j3))*math.sin(j1),
 98                self.base_z + self.link1*math.cos(j2) + self.link2*math.cos(j2 + j3)]
 99
100    #================================================================
101    def endpoint_inverse_kinematics(self, target):
102        """Compute the joint angles for a target end position.  The target is a
103        XYZ Cartesian position vector in body coordinates, and the result vector
104        is a joint angles as list [j1, j2, j3].  If the target is out of reach,
105        returns the closest pose.  With j1 between -pi and pi, and j2 and j3
106        limited to positive rotations, the solution is always unique.
107        """
108
109        x = target[0]
110        y = target[1]
111        z = target[2]
112
113        # the joint1 base Z rotation depends only upon x and y
114        j1 = math.atan2(y, x)
115
116        # distance within the XY plane from the origin to the endpoint projection
117        xy_radial = math.sqrt(x*x + y*y)
118
119        # find the Z offset from the J2 horizontal plane to the end point
120        end_z = z - self.base_z
121
122        # angle between the J2 horizonta plane and the endpoint
123        theta = math.atan2(end_z, xy_radial)
124
125        # radial distance from the J2 axis to the endpoint
126        radius = math.sqrt(x*x + y*y + end_z*end_z)
127
128        # use the law of cosines to compute the elbow angle solely as a function of the
129        # link lengths and the radial distance from j2 to end
130        #   R**2 = l1**2 + l2**2 - 2*l1*l2*cos(pi - elbow)
131        acosarg = (radius*radius - self.link1**2 - self.link2**2) / (-2 * self.link1 * self.link2)
132        if acosarg < -1.0:  elbow_supplement = math.pi
133        elif acosarg > 1.0: elbow_supplement = 0.0
134        else:               elbow_supplement = math.acos(acosarg)
135
136        print("theta:", theta, "radius:", radius, "acosarg:", acosarg)
137
138        # use the law of sines to find the angle at the bottom vertex of the triangle defined by the links
139        #  radius / sin(elbow_supplement)  = l2 / sin(alpha)
140        if radius > 0.0:
141            alpha = math.asin(self.link2 * math.sin(elbow_supplement) / radius)
142        else:
143            alpha = 0.0
144
145        # calculate the joint angles
146        return [j1, math.pi/2 - theta - alpha, math.pi - elbow_supplement]
147
148
149    #================================================================
150    # motion primitives
151
152    def go_joints(self, target):
153        """Issue a position command to move to the given endpoint position expressed in joint angles."""
154
155        self.motor1.setPosition(target[0])
156        self.motor2.setPosition(target[1])
157        self.motor3.setPosition(target[2])
158        # print("%s: moving to (%f, %f, %f)" % (self.robot_name, target[0], target[1], target[2]));
159
160
161    #================================================================
162    # Polling function to process sensor input at different timescales.
163    def poll_sensors(self):
164        self.end_sensor_timer -= EVENT_LOOP_DT
165        if self.end_sensor_timer < 0:
166            self.end_sensor_timer += self.end_sensor_interval
167
168            # read the distance sensor
169            distance = self.end_sensor.getValue()
170
171            if distance < 0.9:
172                # print("%s: range sensor detected obstacle at %f." % (self.robot_name, distance))
173                pass
174
175    #================================================================
176
177    # Define a joint-space movement sequence as a Bezier cubic spline trajectory
178    # specified in degrees.  This should have three rows per spline segment.
179
180    _path = np.array([               # the first waypoint is implicitly zero
181                      [  0,  0,  0],
182                      [  5, 30, 30],
183                      [  5, 30, 30], # waypoint
184                      [  5, 30, 30],
185                      [  5, 30, 30],
186                      [  5, 30, 90], # waypoint
187                      [  5, 30, 30],
188                      [  5, 30, 30],
189                      [  5, 30, 30], # waypoint
190                      [  5, 30, 30],
191                      [  0,  0,  0],
192                      [  0,  0,  0], # waypoint
193                      [  0,  0,  0],
194                      [ 45, 30, 30],
195                      [ 45, 30, 30], # waypoint
196                      [ 45, 30, 30],
197                      [ 45, 30, 30],
198                      [ 45, 30, 90], # waypoint
199                      [ 45, 30, 30],
200                      [ 45, 30, 30],
201                      [ 45, 30, 30], # waypoint
202                      [ 45, 30, 30],
203                      [  0,  0,  0],
204                      [  0,  0,  0], # waypoint (should be zero for continuity)
205                      ])
206
207    def _init_spline(self):
208        self.interpolator = bezier.PathSpline(axes=3)
209        self.interpolator.set_tempo(30.0)
210        self.interpolator.add_spline(self._path)
211        self._last_segment_count = self.interpolator.segments()
212
213    def poll_spline_path(self):
214        """Update function to loop a cubic spline trajectory."""
215        degrees = self.interpolator.update(dt=EVENT_LOOP_DT*0.001)
216        radians = [math.radians(theta) for theta in degrees]
217
218        # mirror the base rotation of the right robot for symmetric motion
219        if 'right' in self.robot_name:
220            radians[0] *= -1
221
222        self.go_joints(radians)
223        # print("u: ", self.interpolator.u, "knots:", self.interpolator.knots.shape[0])
224
225        segment_count = self.interpolator.segments()
226        if segment_count != self._last_segment_count:
227            self._last_segment_count = segment_count
228            print("Starting next spline segment.")
229
230        if self.interpolator.is_done():
231            print("Restarting the spline path.")
232            self.interpolator.add_spline(self._path)
233
234    #================================================================
235    # Define joint-space movement sequences.  For convenience the joint angles
236    # are specified in degrees, then converted to radians for the controllers.
237    _right_poses = [[0, 0, 0],
238                    [-45, 0, 60],
239                    [45, 60, 60],
240                    [0, 60, 0],
241                    ]
242
243    _left_poses = [[0, 0, 0],
244                   [45, 0, 60],
245                   [-45, 60, 60],
246                   [0, 60, 0],
247                   ]
248
249    #================================================================
250    def poll_sequence_activity(self):
251        """State machine update function to walk through a series of poses at regular intervals."""
252
253        # Update the state timer
254        self.state_timer -= EVENT_LOOP_DT
255
256        # If the timer has elapsed, reset the timer and update the outputs.
257        if self.state_timer < 0:
258            self.state_timer += 2000
259
260            # Look up the next pose.
261            if 'left' in self.robot_name:
262                next_pose = self._left_poses[self.state_index]
263                self.state_index = (self.state_index + 1) % len(self._left_poses)
264            else:
265                next_pose = self._right_poses[self.state_index]
266                self.state_index = (self.state_index + 1) % len(self._right_poses)
267
268            # Convert the pose to radians and issue to the motor controllers.
269            angles = [math.radians(next_pose[0]), math.radians(next_pose[1]), math.radians(next_pose[2])]
270            self.go_joints(angles)
271
272
273   #================================================================
274    def run(self):
275        # Run loop to execute a periodic script until the simulation quits.
276        # If the controller returns -1, the simulator is quitting.
277        while self.step(EVENT_LOOP_DT) != -1:
278            # Read simulator clock time.
279            self.sim_time = self.getTime()
280
281            # Read sensor values.
282            self.poll_sensors()
283
284            # Update the activity state machine.
285            # self.poll_sequence_activity()
286
287            # Update the spline trajectory generator.
288            self.poll_spline_path()
289
290
291################################################################
292# Start the script.
293robot = ZYY()
294robot.run()