Webots Robot Simulator
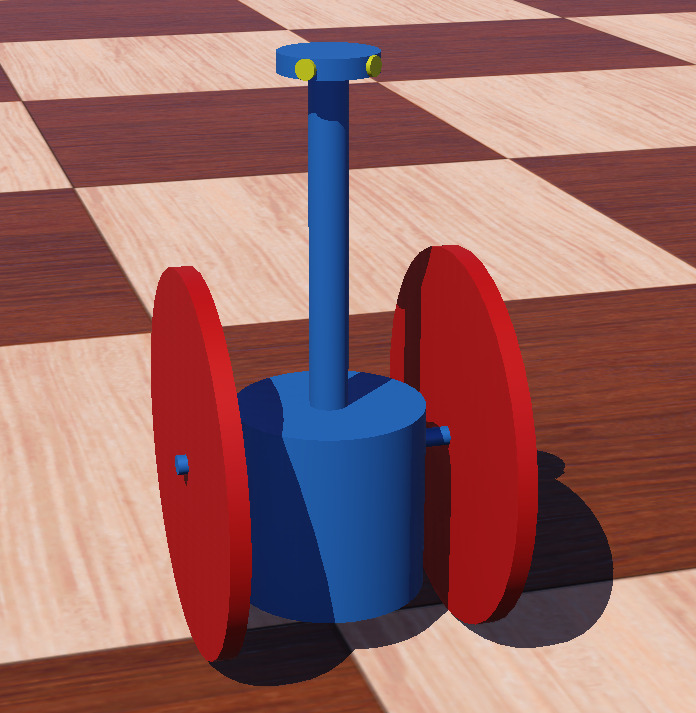
We will use the Webots robot simulator for exploratory exercises. The following pages document the sample simulations provided as reference, including robot models, world definitions, and control code.
All samples are maintained in a single large project, available as a zip file Webots.zip. Webots requires the project files in a specific structure so unpacking this zip will yield a valid project with multiple individual world files. For basic descriptions of the worlds, please see Webots Demo Worlds.
For inspection, individual files can be examined in the Webots project file tree.
To get started, please see Webots Installation.
- Webots Robot Simulator Documentation
- Webots Installation
- Robot Simulation Design
- Webots Modeling
- Open Loop Functions
- Wobbly Robot Model
- Mobility Machine Demo
- Boom-Monopod Model
- Arm Theater
- Two-Link Robot Model
- ZYY Robot Arm Model
- Arm Camera
- Menagerie World
- Clock Robot Model
- Array
- Shutterbox
- Pendulum de Deux
- Suitcase Robot Model
- Impeller Array
- Curtain
- Tilt Table
- Dobot Magician Lite
- Conveyor
- Impeller Robot Model
- Pendulum 1-2 Robot Model
- Delegate Robot Model
- Proxy Robot Model
- Webots Demo Worlds
- MuJoCo Simulator